Overview
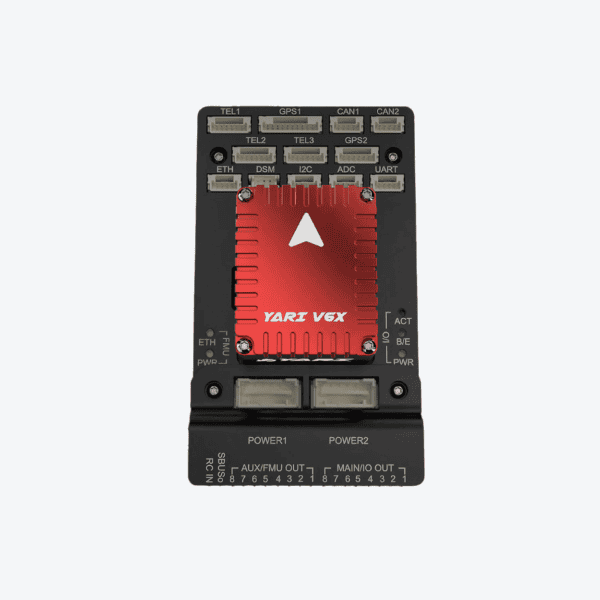
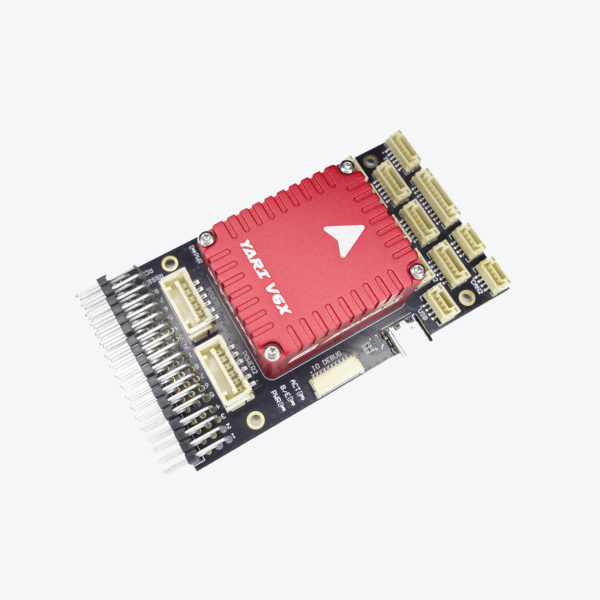
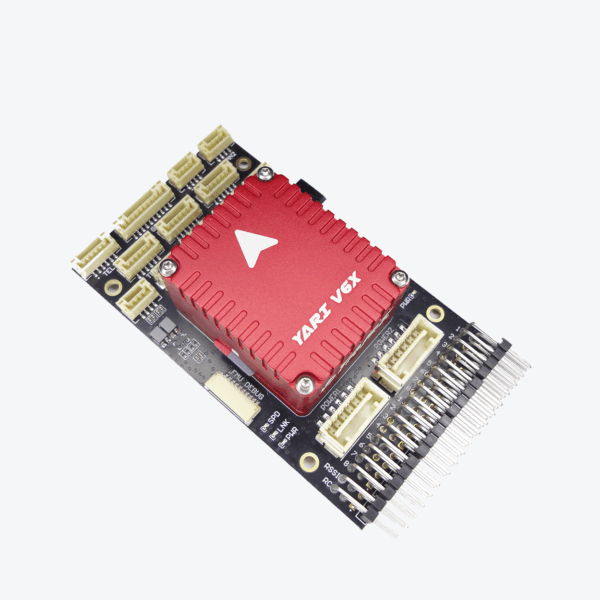
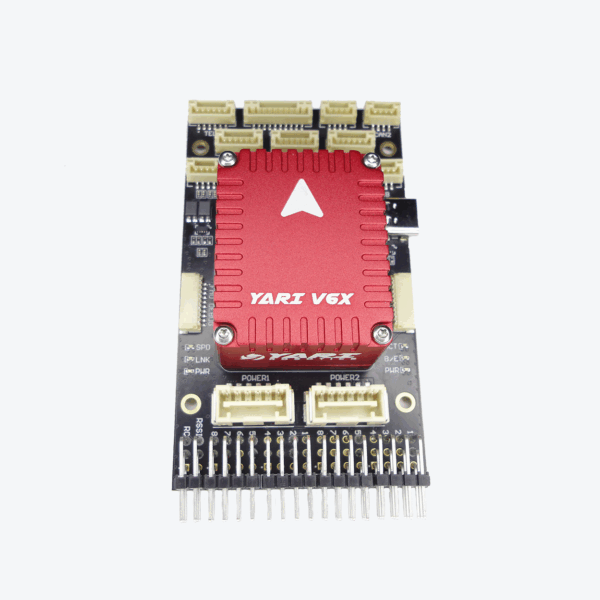
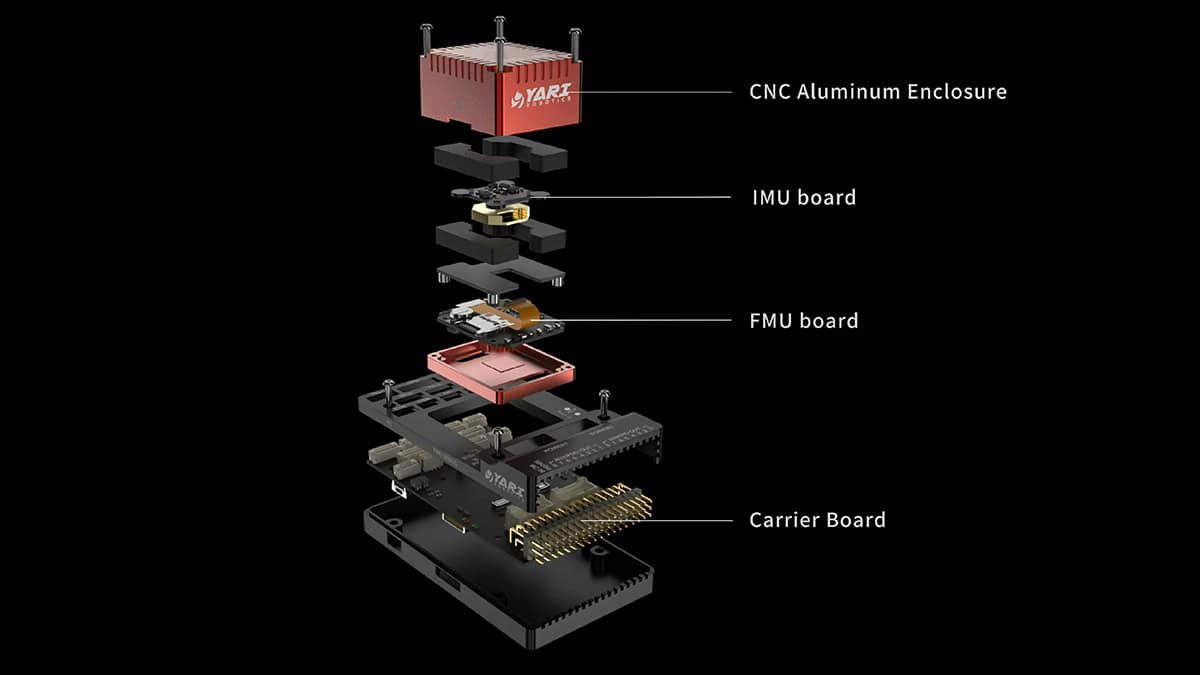
The YARI V6X Flight Controller is supplied as a standard set: the YARI V6X FMU/IMU autopilot module installed on its YARI PAB carrier board. It is built on the FMUv6X and Pixhawk Autopilot Bus (PAB) open-source standards.
The PAB architecture keeps the sensor/FMU module and carrier-board interfaces modular. The supplied carrier board is the supported wiring and power interface for this product; see the documentation pinout before connecting peripherals or power.
Designed for industrial and commercial unmanned systems, the YARI V6X provides high-precision navigation, robust sensor redundancy, and exceptional vibration performance. A thermally stabilized, triple-IMU architecture ensures accurate state estimation even under harsh vibration or environmental conditions.
Key Features
- Standard-set architecture: A YARI V6X FMU/IMU autopilot module and YARI PAB carrier board provide the complete flight-controller and peripheral interface system.
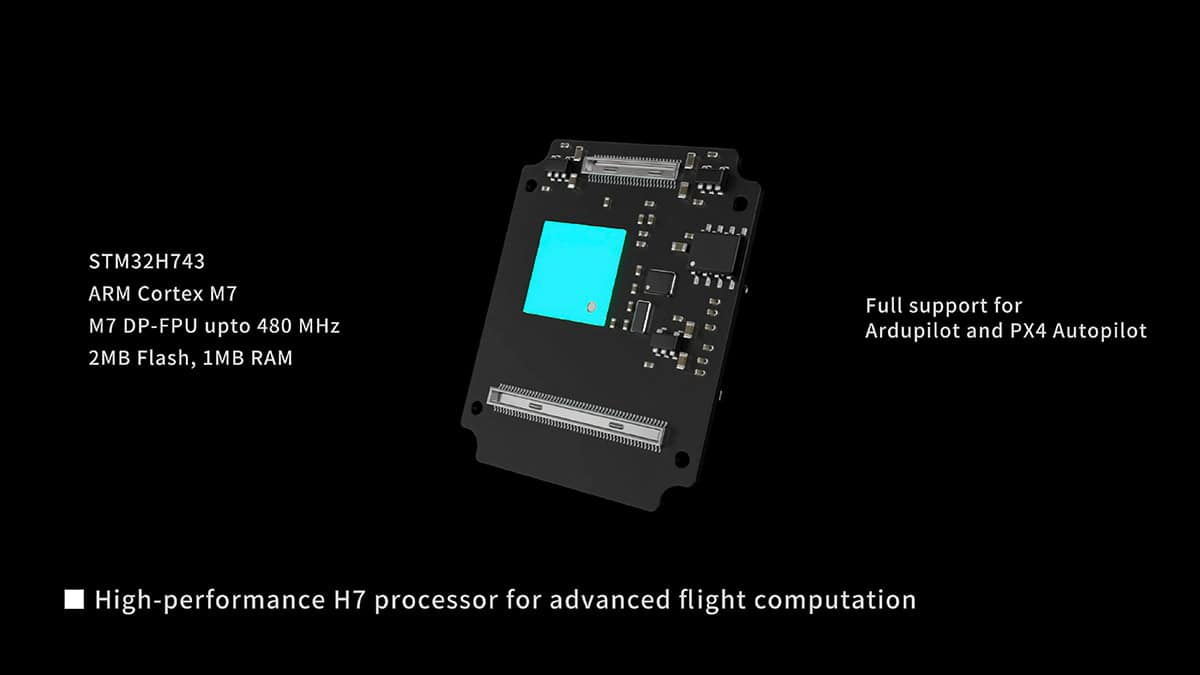
- Main and I/O processors: STM32H743IIK6 main processor and STM32F103 I/O coprocessor.
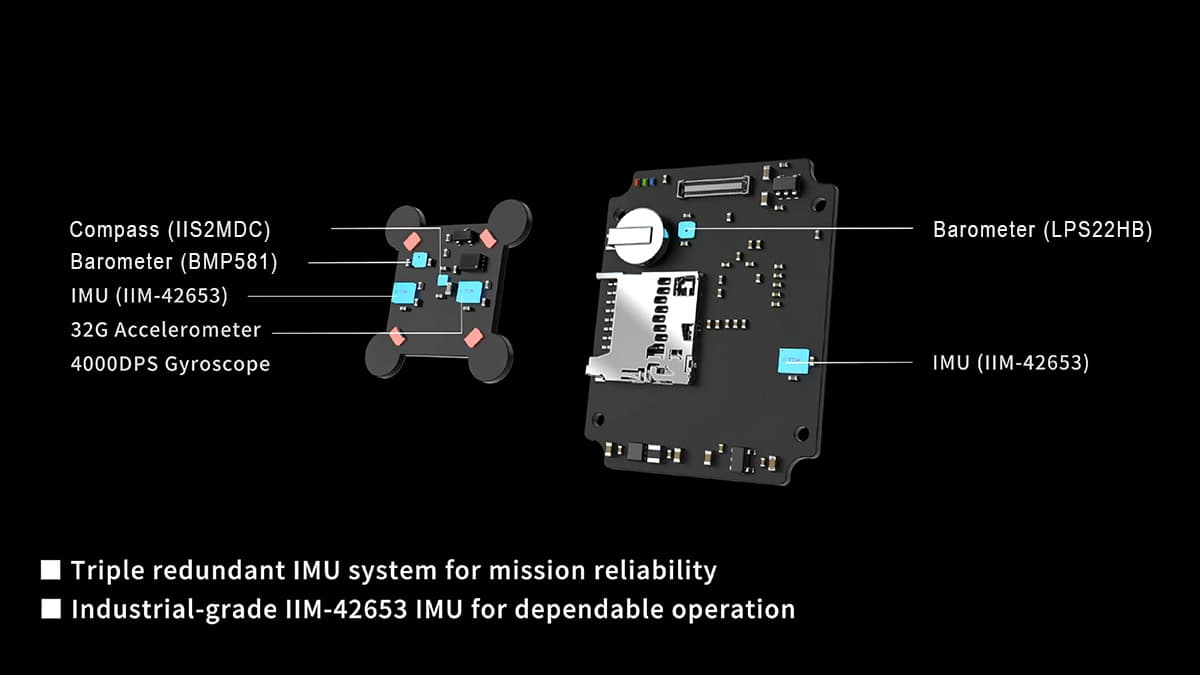
- Redundant IMUs: Three TDK InvenSense IIM-42653 IMUs provide redundant inertial sensing.
- Navigation sensors: Bosch BMP581 and STMicroelectronics LPS22HB barometers, plus an STMicroelectronics IIS2MDC magnetometer.
- Redundant power architecture: POWER1 and POWER2 inputs provide prioritized, redundant 5 V power input.
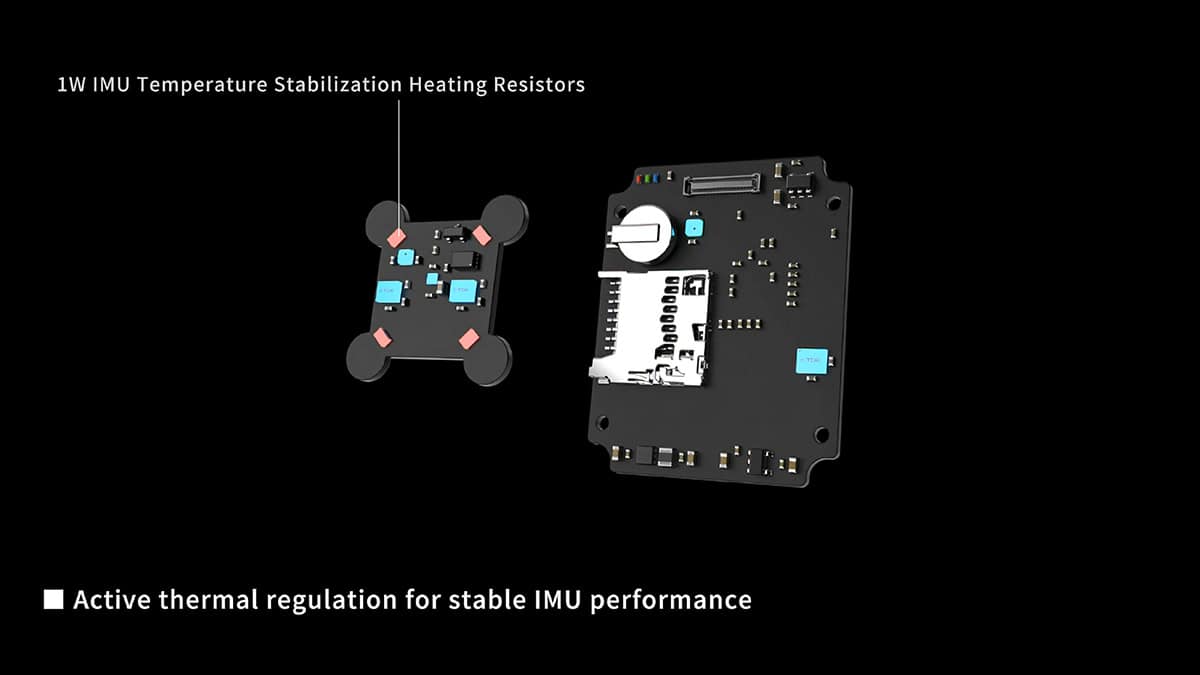
- Thermal control: 1 W active IMU heating supports consistent sensor performance across changing temperatures.
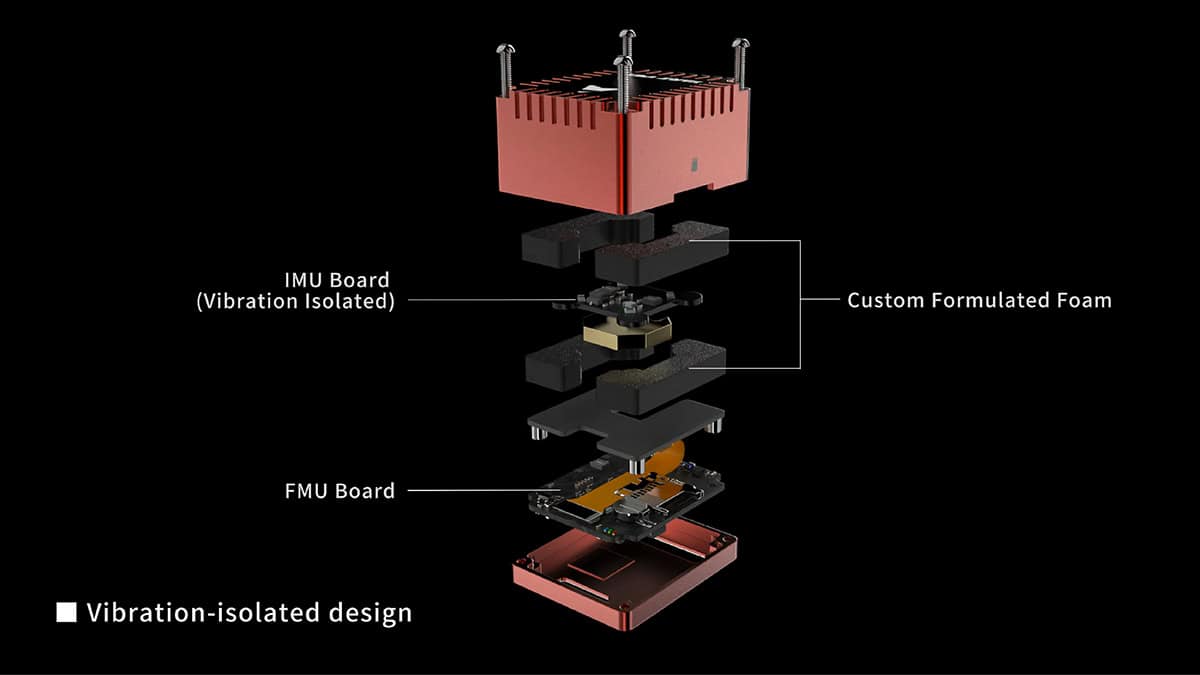
- Vibration isolation: An IMU vibration-damping system reduces vibration transmission for more stable state estimation.
- Ethernet: 100 Mbps Ethernet supports MAVLink and companion-computer integration.
- Firmware support: ArduPilot is supplied by default, with PX4 flashable.
- Rugged aluminum enclosure: CNC-machined metal housing improves thermal performance, mechanical durability, and EMI resistance.
Built for multirotors, fixed-wing aircraft, VTOLs, ground vehicles, and marine/ROV platforms.
Specifications
| Firmware | |
|---|---|
| Supported firmware | ArduPilot (default) PX4 (flashable) |
| Sensors | |
| IMUs | 3x TDK InvenSense IIM-42653 |
| Barometer | 1x Bosch BMP581 + 1x STMicroelectronics LPS22HB |
| Magnetometer | 1x STMicroelectronics IIS2MDC |
| Heater | 1 W heater |
| Processing & Storage | |
| Main processor | STM32H743, 480 MHz, 2 MB Flash, 1 MB RAM |
| I/O coprocessor | STM32F103, 72 MHz, 64 KB SRAM |
| FRAM | 256 KB |
| MicroSD | Included 32 GB card |
| Interfaces & Connectivity | |
| Power inputs | POWER1 and POWER2: 6-pin Molex CLIK-Mate digital power-module ports, each rated for 5 V, 6 A, with I2C power-monitor bus USB-C and 4-pin JST-GH USB: parallel regulated 5 V inputs |
| GNSS | GPS1: 10-pin JST-GH with UART, I2C, safety-switch, LED, and buzzer signals GPS2: 6-pin JST-GH with UART and I2C |
| Telemetry & UART | 3x 6-pin JST-GH telemetry ports with TX/RX/CTS/RTS 1x 4-pin JST-GH UART port |
| CAN | 2x 4-pin JST-GH CAN ports with 5 V, CAN-H, CAN-L, and GND |
| Ethernet | 100 Mbps (100BASE-TX) Ethernet through a 4-pin JST-GH port for use with a compatible RJ45 adapter or cable |
| USB | USB-C port and 4-pin JST-GH USB interface |
| RC input | 3-pin servo-rail RC input, 4-pin JST-GH RC port, and 3-pin DSM input |
| PWM outputs | M1-M8 main and A1-A8 auxiliary PWM positions, plus SBUS output Bidirectional DShot is available on A1-A6 |
| Peripheral expansion | 4-pin JST-GH I2C port and 4-pin JST-GH ADC port with one 3.3 V-tolerant and one 6.6 V-tolerant analog input |
| Debug | 10-pin IO debug and 10-pin FMU debug ports |
| Electrical & Environmental | |
| Autopilot module power | 5 V, 500 mA (300 mA system, 200 mA heater) |
| Carrier-board power input & protection | POWER1 and POWER2: each rated for 5 V, 6 A USB-C and USB JST-GH: regulated 5 V inputs Priority: POWER1 > POWER2 > USB USB-C and USB JST-GH are in parallel Overvoltage protection at 5.8 V Undervoltage protection at 3.9 V |
| Operating temperature | -25 °C to 85 °C |
| Mechanical | |
| Standard-set dimensions (with enclosure) | 93.6 × 54.1 × 30.9 mm |
| Weight | 81 g |
| Other | |
| Country of origin | India |
Note: Older YARI V6X hardware revisions may continue to ship while stock lasts. For revision-specific specifications, compatibility, and setup details, see the YARI V6X documentation.
Validation and Testing
YARI V6X has been validated through field flight testing and NABL-accredited lab testing where applicable, including environmental and EMC checks. See the Compliance & Testing summary for more details.
Package Includes
- YARI V6X FMU/IMU autopilot module
- YARI PAB carrier board
- 32 GB microSD card
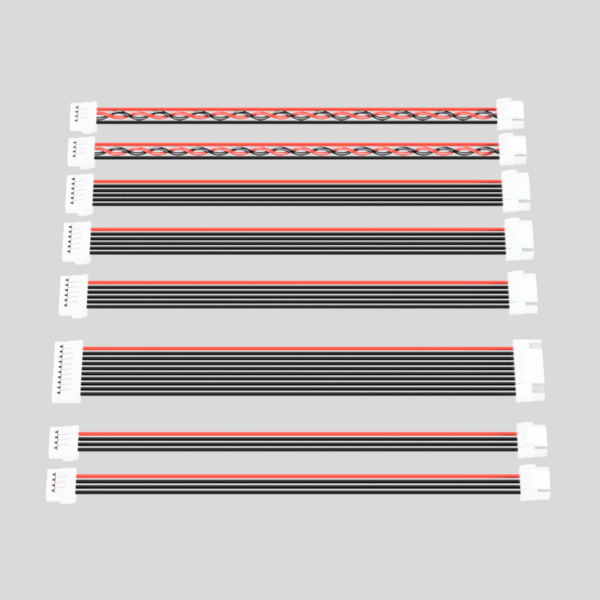
- YARI V6X cable set
- YARI PAB Power Module with 6-pin Molex power cable
Any accessories beyond the listed standard-set contents must be purchased separately.
Documentation
https://docs.yarirobotics.com/products/flight-controllers/yari-v6x/