Overview
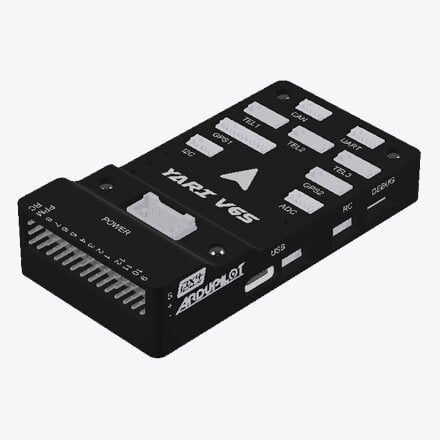
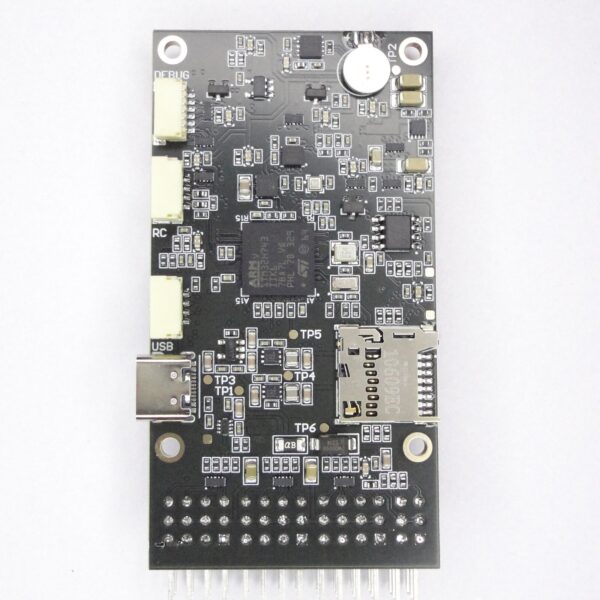
YARI V6S is an affordable flight controller based on the Pixhawk FMUv6 architecture. It is intended for students, academic teams, and researchers who need a modern STM32H743-based platform with ArduPilot and PX4 Autopilot firmware.
It is a practical replacement for older Pixhawk 2.4.8-era FMUv3 controllers in projects that require current-generation hardware and PX4 Autopilot compatibility. YARI V6S is deliberately a single-sensor design: it does not include redundant sensors, sensor heating, or vibration isolation. Choose YARI V6X instead when your vehicle requires those redundancy and robustness features.
The “S” in YARI V6S is intentionally open to interpretation: Simple, Single, Standard, or Small. It describes the product’s focused approach, a practical lower-cost entry point to current FMUv6 hardware for builders who do not need the redundant architecture of YARI V6X.
Key Features
- Current firmware headroom: The STM32H743 runs at up to 480 MHz with 2 MB Flash and 1 MB RAM, providing the capacity for current, fully featured ArduPilot and PX4 Autopilot firmware builds.
- Modern navigation sensing: The latest-generation IMU, barometer, and magnetometer deliver wide measurement ranges and low-noise sensor data for reliable state estimation in a focused single-sensor architecture.
- RPM-aware motor control: Bidirectional DShot on outputs 1–6 can return ESC RPM data for dynamic notch filtering when supported by the ESC and configured firmware, helping reduce motor-vibration effects.
- Companion-computer ready: Serial ports including TELEM, UART, USB-C, and USB JST-GH support MAVLink telemetry and companion-computer integration, including supported DDS and ROS 2 workflows.
- One controller across vehicle types: Built for multirotors, fixed-wing aircraft, VTOLs, ground vehicles, and marine/ROV platforms.
Technical Specifications
| Firmware | |
|---|---|
| Supported firmware | ArduPilot (default) PX4 Autopilot (flashable) |
| Sensors | |
| IMU | 1× TDK InvenSense ICM-45686 Accelerometer range up to ±32 g Gyroscope range up to ±4000 dps 70 µg/√Hz accelerometer noise 3.8 mdps/√Hz gyroscope noise |
| Barometer | 1× Bosch BMP581 300–1250 hPa range ±0.30 hPa absolute accuracy ±0.06 hPa relative accuracy 0.0008 hPa pressure noise |
| Magnetometer | 1× iSentek IST8310 ±1600 µT X/Y and ±2500 µT Z measurement range Up to 200 Hz output 3.3 LSB/µT sensitivity |
| Processing and Storage | |
| Processor | STM32H743 480 MHz 2 MB Flash 1 MB RAM |
| microSD | Included 32 GB card |
| Interfaces | |
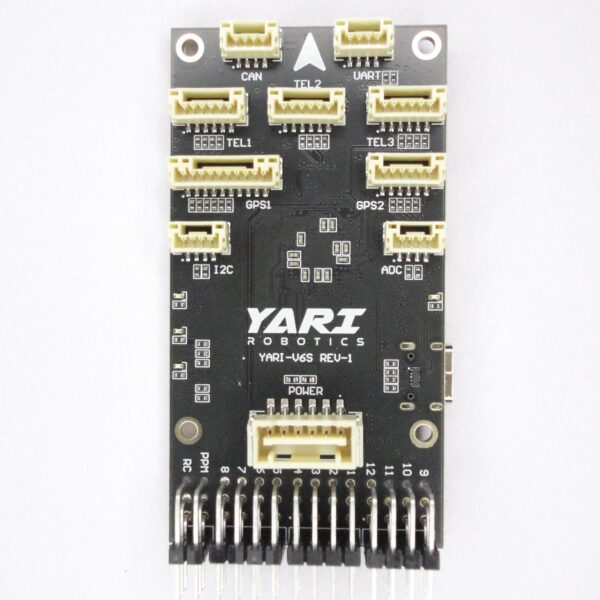
| Serial and peripheral ports | 3× TELEM 1× UART 1× RC 1× USB 1× USB-C 1× FMU DEBUG |
| Navigation and expansion ports | 1× GPS1 1× GPS2 1× CAN 1× I2C 1× ADC |
| Actuator outputs | 12 PWM outputs Bidirectional DShot on outputs 1–6 |
| Mechanical and Electrical | |
| Power inputs | 1× POWER port, +5.0 V, 6 A USB-C and USB JST-GH regulated +5.0 V inputs wired in parallel POWER has priority over USB |
| Peripheral power | +5.0 V, 1.5 A total |
| Operating-current specification | Not yet published |
| Product dimensions | 82.8 × 44 × 18.2 mm |
| Weight | Not yet published |
| Other | |
| Country of origin | India |
Package Includes
- YARI V6S Flight Controller
- YARI V6S Cable Set
- 32 GB microSD Card
Note: Enclosure not included. Refer to the documentation for the enclosure CAD model for 3D printing.
Compared with Typical Pixhawk 2.4.8 Boards
YARI V6S is designed as a current-generation alternative to the Pixhawk 2.4.8-style FMUv3 boards widely available in India. Pixhawk 2.4.8 is produced by many vendors, so its exact MCU, sensor set, component authenticity, and protection circuitry can vary. The comparison below describes a common configuration.
| Area | YARI V6S | Typical Pixhawk 2.4.8 board sold in India |
|---|---|---|
| MCU | STM32H743 Arm Cortex-M7, up to 480 MHz, 2 MB Flash, and 1 MB RAM | STM32F427-class Arm Cortex-M4, typically 168 MHz, 1 MB Flash, and 192 KB RAM |
| IMU | TDK InvenSense ICM-45686 6-axis IMU; accelerometer range up to ±32 g, gyro range up to ±4000 dps, 70 µg/√Hz accelerometer noise, and 3.8 mdps/√Hz gyro noise | Commonly MPU6000 and L3GD20H-class sensors; MPU6000 acceleration range up to ±16 g and gyro range up to ±2000 dps, 400 µg/√Hz accelerometer noise, and 5 mdps/√Hz gyro noise. L3GD20H gyro noise is 11 mdps/√Hz. |
| Barometer | Bosch BMP581; 300–1250 hPa range, ±0.30 hPa absolute accuracy, ±0.06 hPa relative accuracy, and 0.0008 hPa pressure noise | Commonly MS5611; 10–1200 hPa range, ±1.5 hPa accuracy at 25 °C/750 hPa, and 0.012 hPa RMS resolution at OSR 4096 |
| Compass | iSentek IST8310 3-axis AMR magnetometer; ±1600 µT X/Y and ±2500 µT Z measurement range, with 1% typical X-axis and 0.1% typical Y/Z linearity. | Commonly HMC5883L- or QMC5883L-class 3-axis compass; QMC5883L provides ±800 µT range, 0.2 µT field resolution, and 1°–2° stated heading accuracy |
| Port protection and power filtering | ESD protection on all exposed ports. Each peripheral +5 V rail is filtered to reduce conducted high-frequency noise before it reaches downstream peripherals. | No ESD protection or equivalent peripheral +5 V feed-through filtering. |
| Firmware platform | Latest ArduPilot and PX4 Autopilot firmware (FMUv6) | ArduPilot (FMUv3) PX4 Autopilot: Not supported |
Note: The figures above describe device-level capabilities. Flight-controller performance also depends on PCB layout, power design, and vehicle integration.
Documentation
https://docs.yarirobotics.com/products/flight-controllers/yari-v6s/overview/