Overview
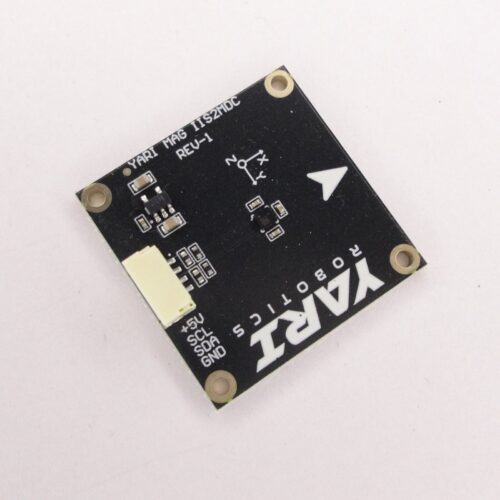
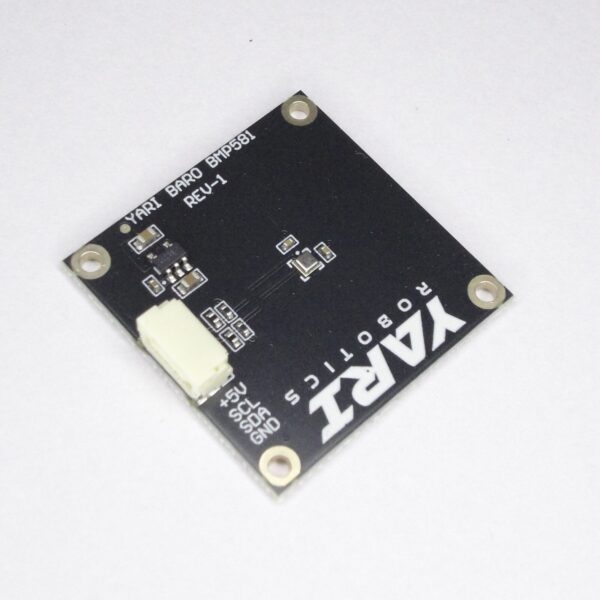
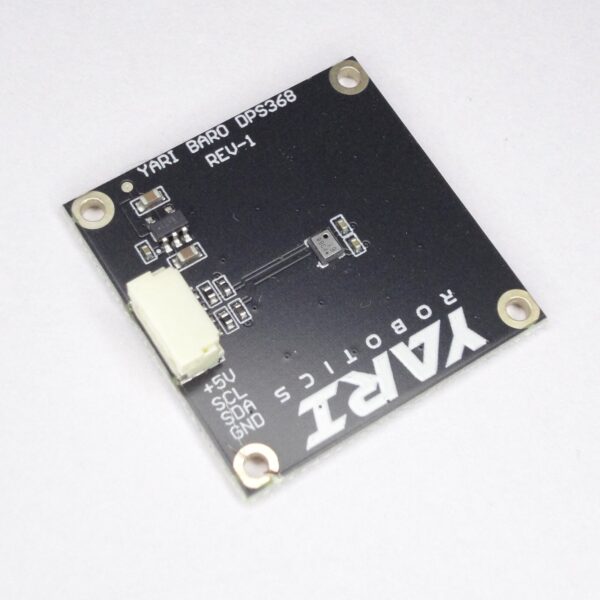
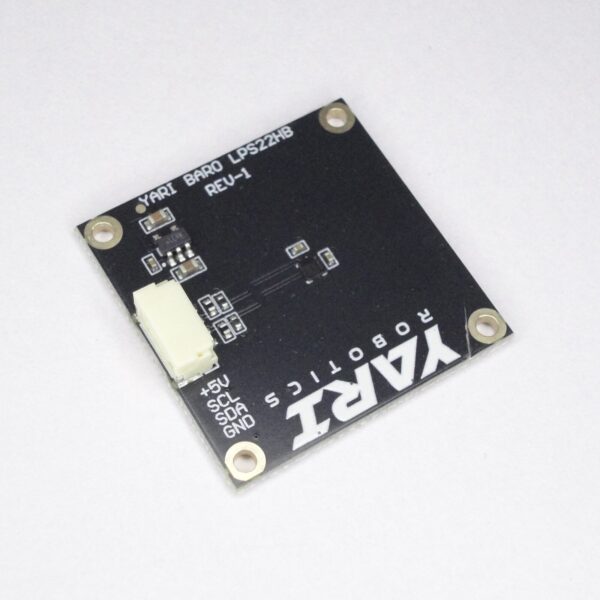
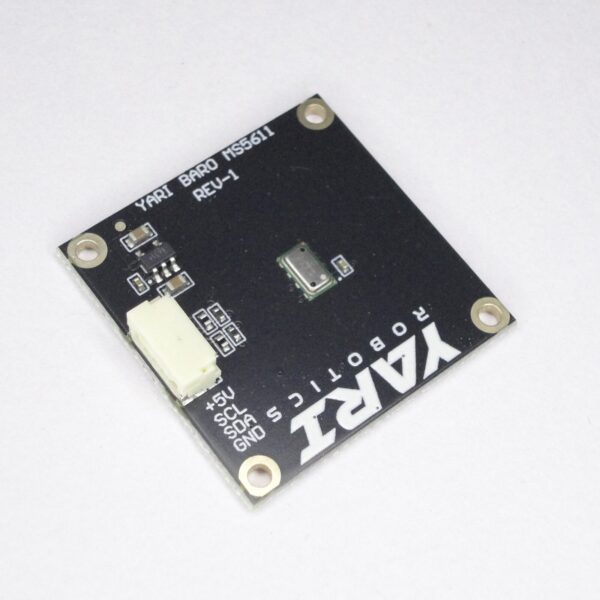
YARI I2C Barometer Sensors provide external pressure sensing for Pixhawk-class flight controllers, including YARI V6X and YARI V6S. Choose from four sensor options: LPS22HB, BMP581, DPS368, and MS5611.
These boards can be used with the GPS1, GPS2, and I2C ports on YARI flight controllers. Each sensor ships with a 4-pin JST-GH connector. For GPS1 or GPS2 use, a custom cable is required; the I2C port provides the direct external-I2C connection.
Refer to the YARI External Sensor Benchmarking guide for integration guidance and the full outdoor comparison results.
Sensor Options
All four available sensor options support I2C.
| Sensor | Pressure range | Datasheet performance | Maximum ODR | Operating temperature |
|---|---|---|---|---|
| LPS22HB | 260-1260 hPa | Relative: ±0.1 hPa; absolute: ±0.1 hPa after one-point calibration; noise: 0.0075 hPa RMS | 75 Hz | -40 to 85 °C |
| BMP581 | 300-1250 hPa | Absolute: ±0.30 hPa; relative: ±0.06 hPa; noise: 0.0008 hPa | 480 Hz | -40 to 85 °C |
| DPS368 | 300-1200 hPa | Absolute: ±1 hPa; relative: ±0.06 hPa; precision: ±0.002 hPa | 200 Hz | -40 to 85 °C |
| MS5611 | 10-1200 hPa | Accuracy: ±1.5 hPa at 25 °C / 750 hPa; resolution: 0.012 hPa RMS at OSR 4096 | Approximately 830 Hz at OSR 256 | -40 to 85 °C |
Datasheet figures use different operating conditions and definitions; use them as design references rather than a directly normalized performance ranking. Refer to the documentation for flight-test results and integration details.
Key Features
- Four external-barometer choices: LPS22HB, BMP581, DPS368, and MS5611 options for different integration requirements.
- YARI flight-controller support: Designed as external I2C sensors for YARI V6X and YARI V6S flight controllers.
- Flexible ports: Use the GPS1, GPS2, or I2C port; GPS-port installations require a custom cable.
- 4-pin JST-GH connection: Supplied with a 4-pin JST-GH connector for external-I2C integration.
- PX4 and ArduPilot drivers: Drivers are included, with firmware setup required when a standard image does not automatically start the selected external sensor.
Firmware and Setup
ArduPilot and PX4 include drivers for these sensors, but default flight-controller firmware may not automatically start every external I2C barometer. Refer to the External Sensor Benchmarking guide to manually start the required driver or build custom firmware. Contact YARI support for a custom firmware build with the selected sensor enabled.
Package Includes
- 1 × Selected YARI I2C Barometer Sensor
- 1 × 4-pin JST-GH connector
Documentation
https://docs.yarirobotics.com/technical-guides/external-sensor-benchmarking/